libgnss++
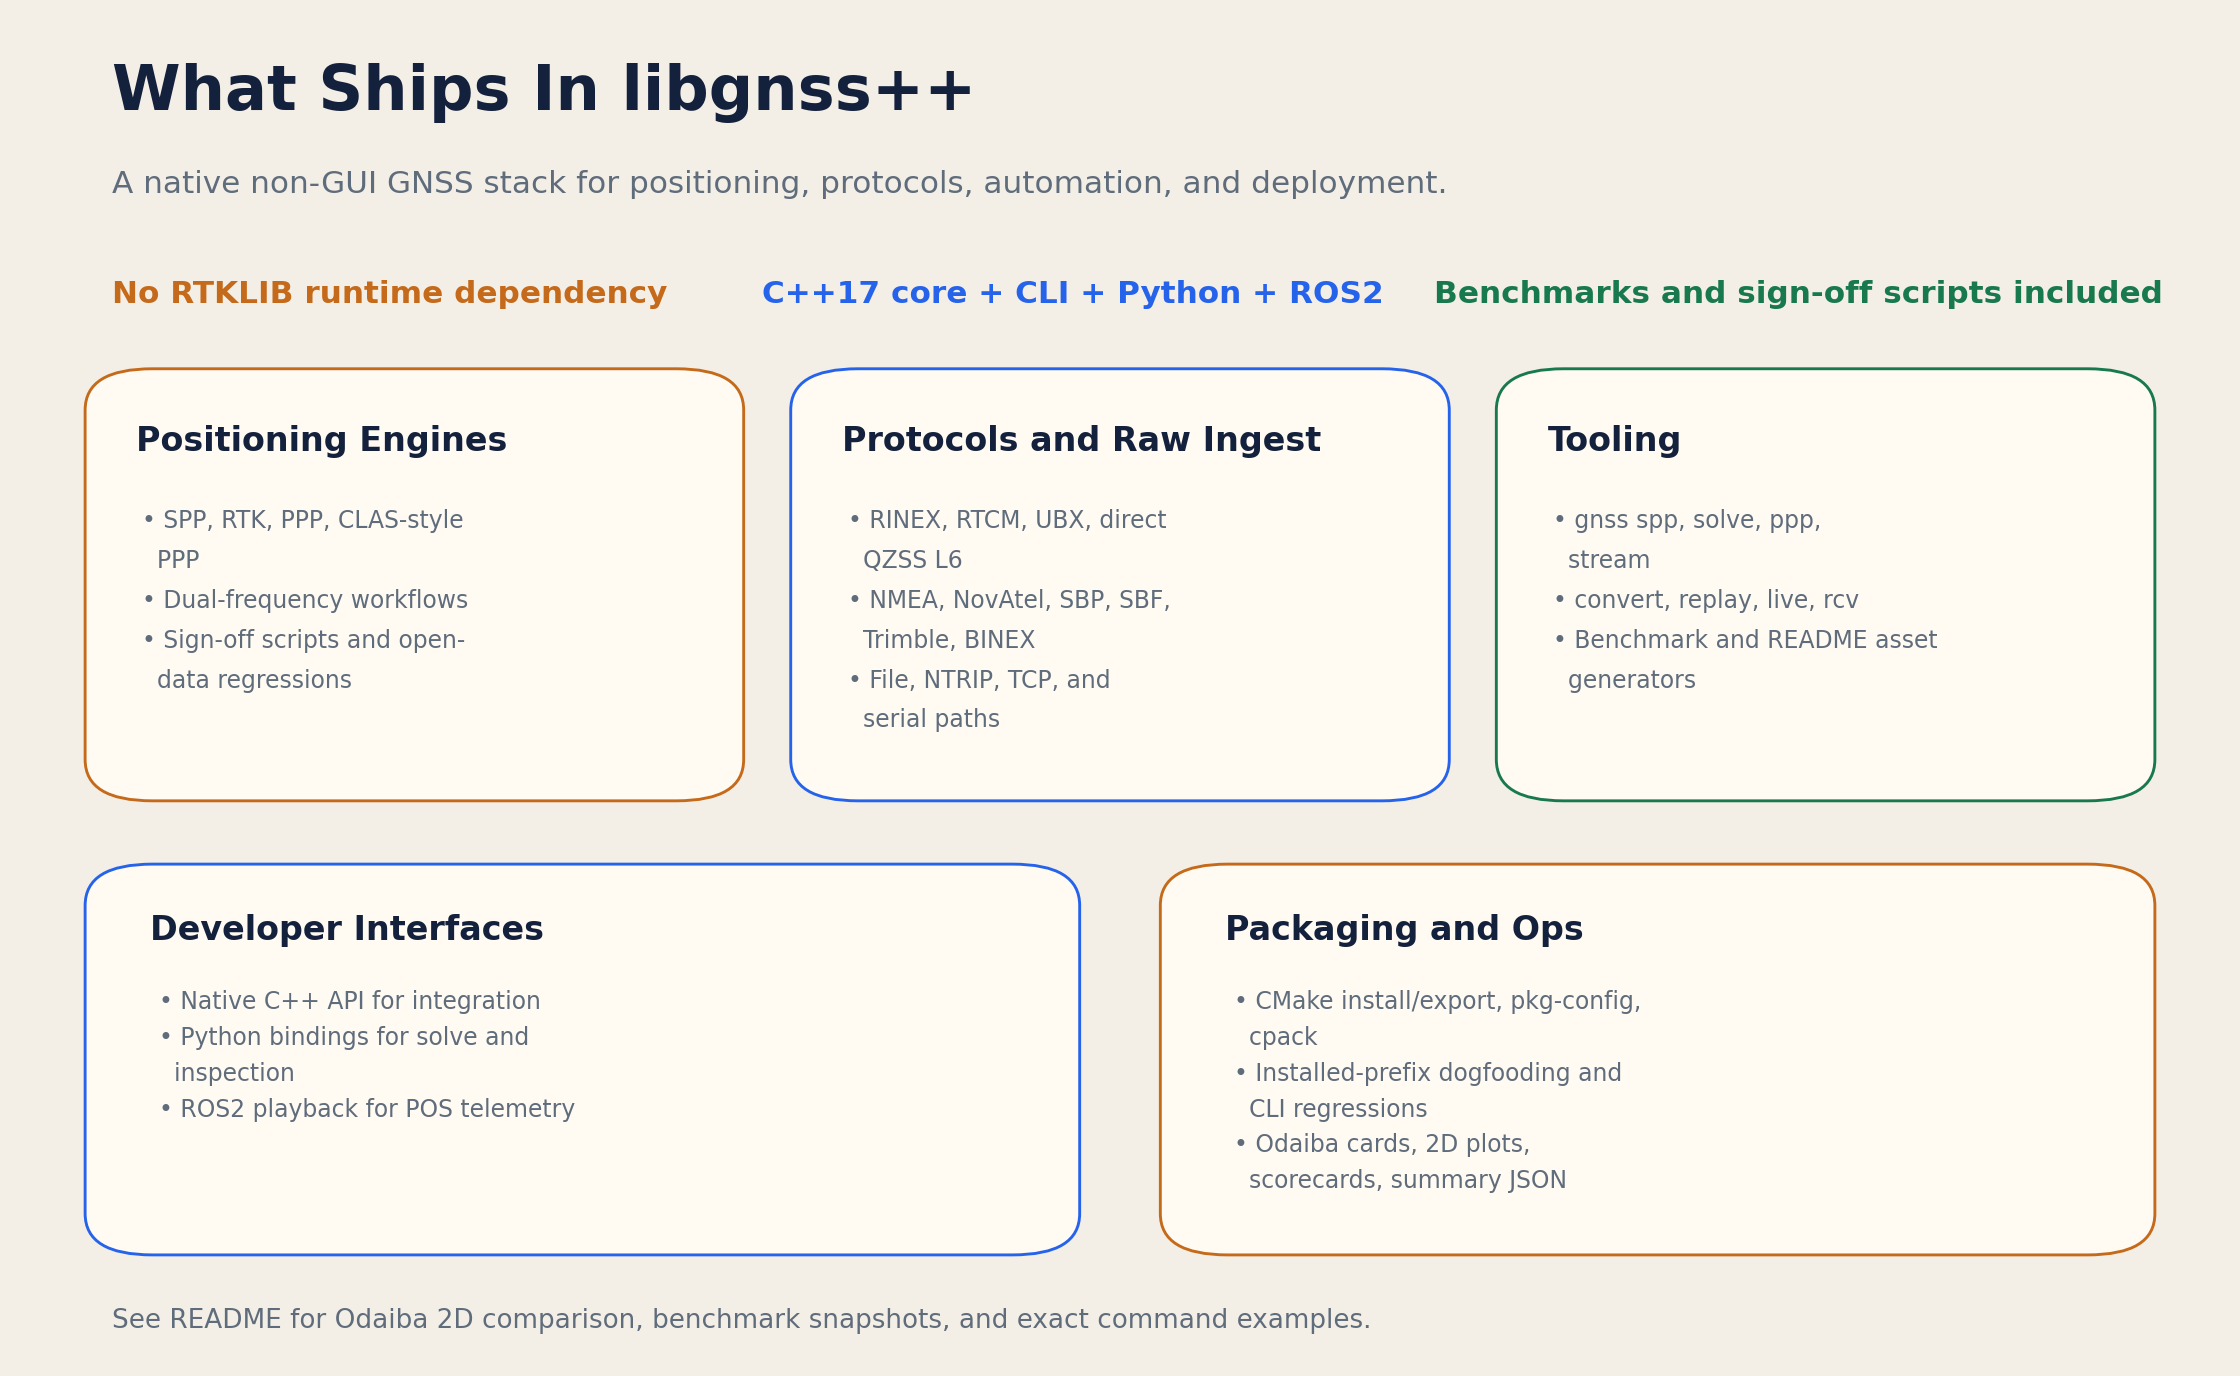
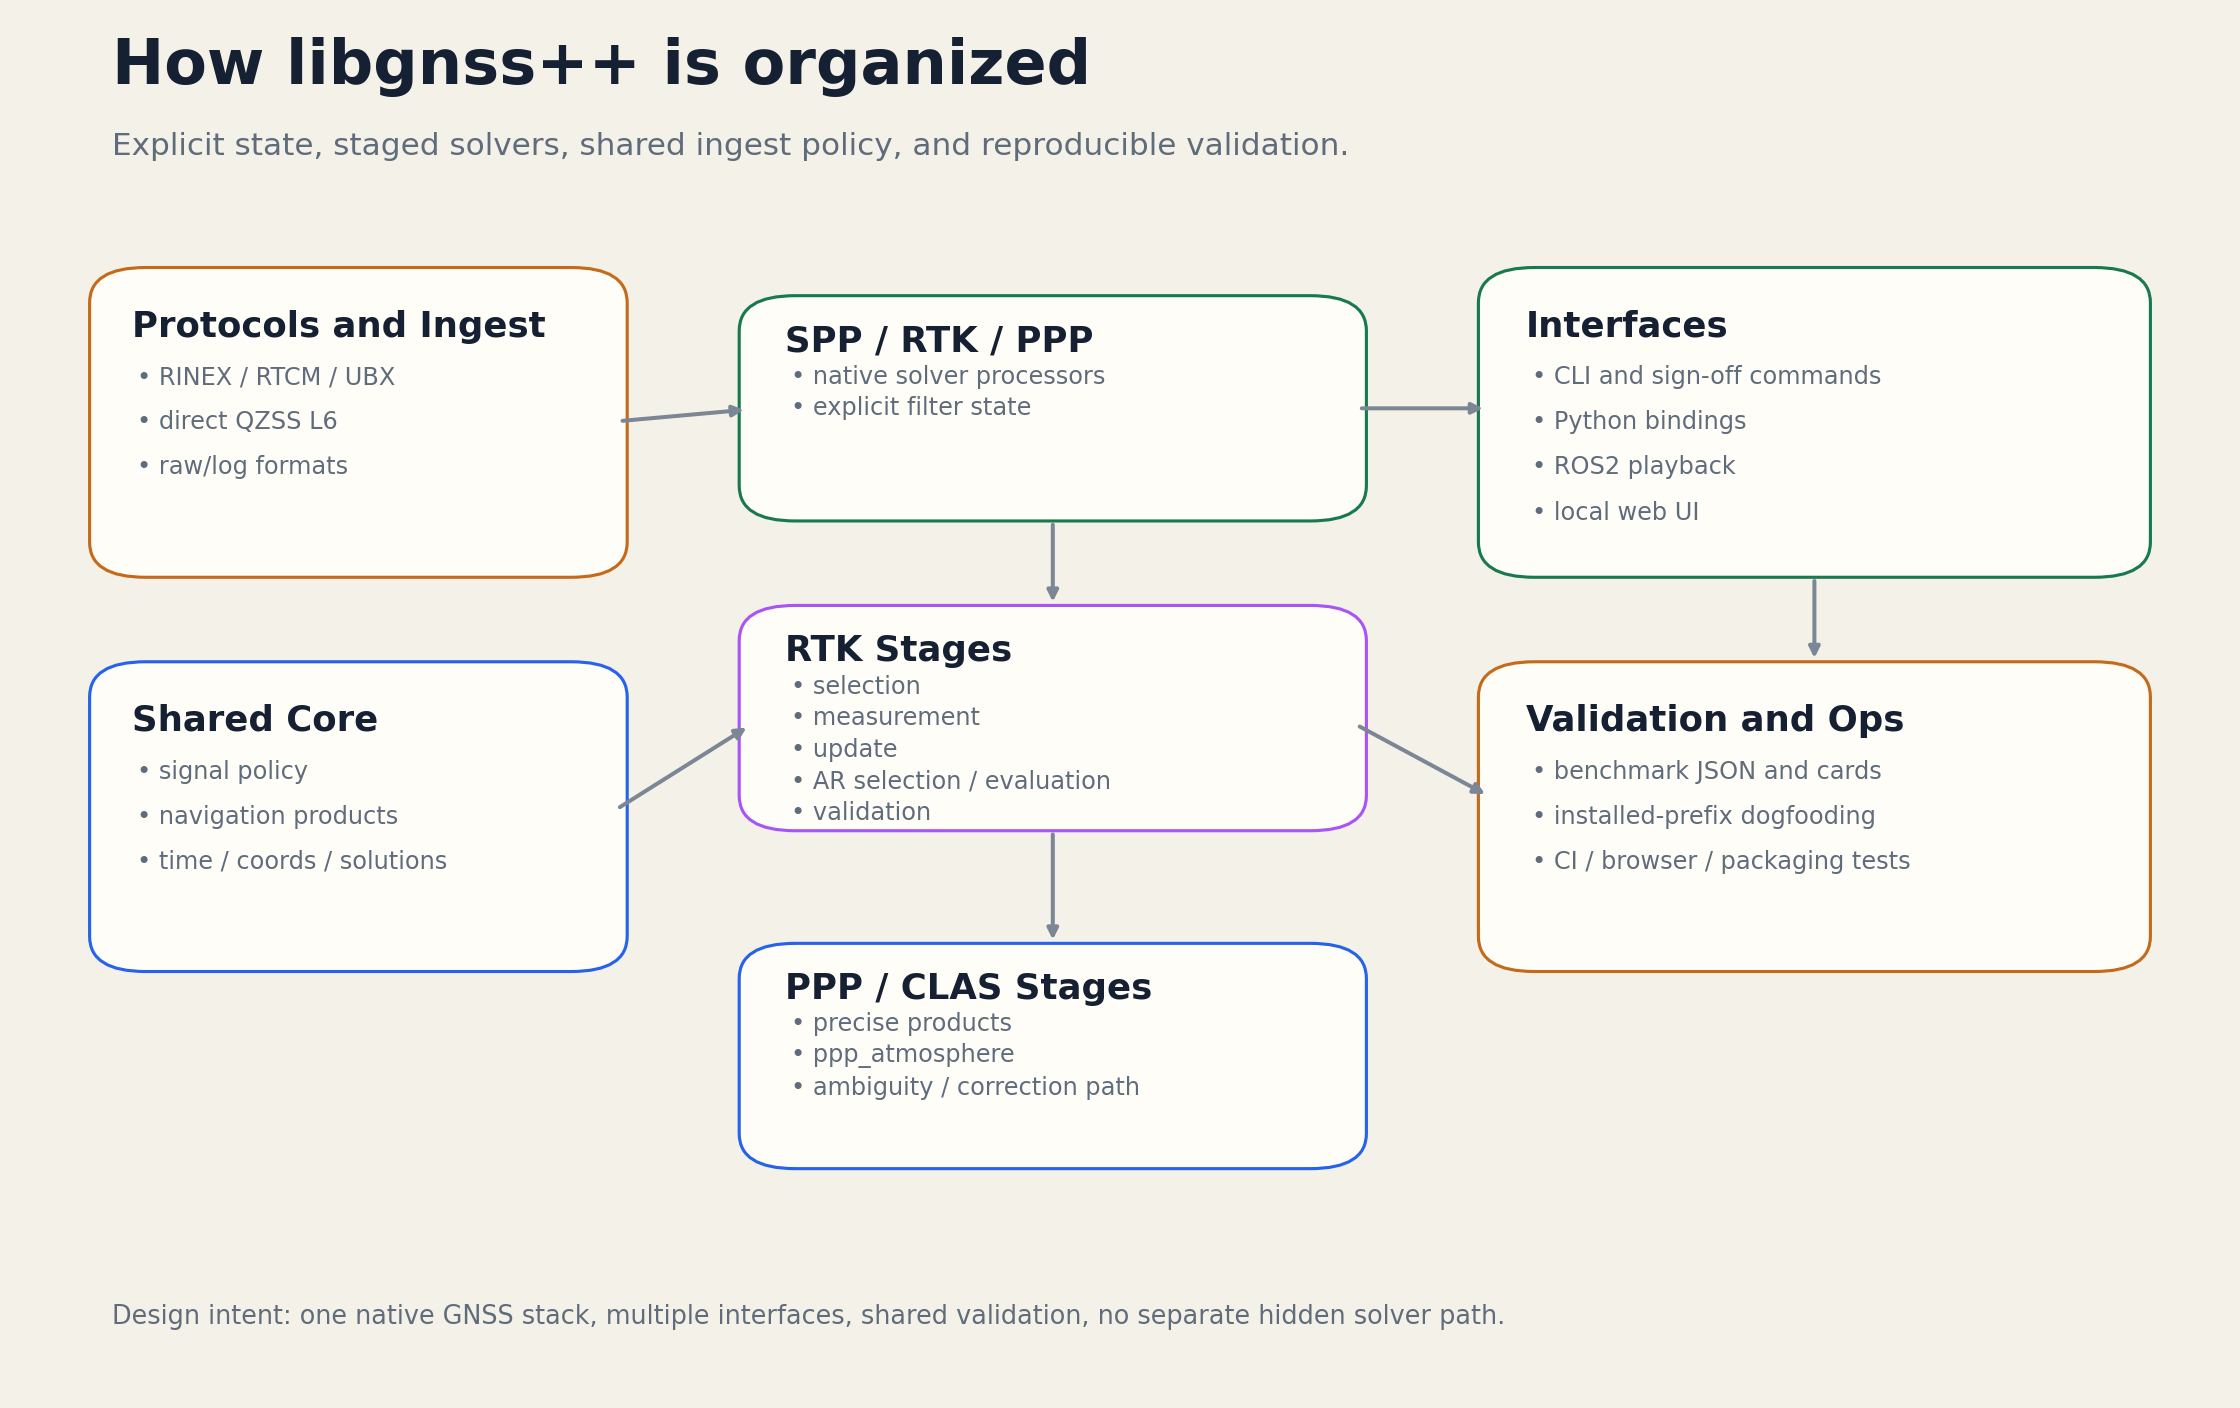
Native C++20 GNSS stack for SPP, RTK, PPP, CLAS/MADOCA, RTCM, UBX, and QZSS L6 — no RTKLIB runtime dependency, no GUI required.
cmake -S . -B build -DCMAKE_BUILD_TYPE=Release && cmake --build build -j
python3 apps/gnss.py doctor
That is it: build, verify your machine, then pick a path below.
Pick your path
| I want to… | Start here | Time |
|---|---|---|
| Get a first solution with bundled data | Quick Start | ~5 min |
| Prove it works with zero installs | Self-contained offline demo | ~1 min |
| Wire GNSS into a robot / ROS2 | Robotics Quick Start | ~10 min |
Move an existing rnx2rtkp job over |
RTKLIB migration | ~10 min |
| Deploy urban RTK with IMU continuity | R1 urban RTK/IMU field checklist | ~15 min |
| Run an auditable static survey (Japan) | Japan static survey | ~15 min |
| Match my dataset / application | Use cases | varies |
Run it in one command (Docker)
No build, no dependencies — mount only the output directory:
docker pull ghcr.io/rsasaki0109/gnssplusplus-library:v0.3.0
mkdir -p output
docker run --rm -v "$PWD/output:/workspace/output" \
  ghcr.io/rsasaki0109/gnssplusplus-library:v0.3.0 \
  demo --output-dir /workspace/output/self-contained-demo
This is an offline plumbing check, not a field-accuracy claim.
What it does
- Positioning: SPP, RTK (static/kinematic/moving-base), PPP, PPP-AR, CLAS/MADOCA.
- Fusion: GNSS + IMU FGO, NHC/ZUPT constraints, integrity gates.
- I/O & interfaces: RINEX 3/4, RTCM, UBX, NTRIP/serial streaming, ROS2, Python, browser UI.
| Understand the design | Validate results | Explore interfaces |
|---|---|---|
| Architecture | Validation & sign-off | Interfaces |
| IMU fusion | Benchmarks | Quick Start commands |
| Tight coupling | PPC reproduction | Experiments |
| Real-time stress harness |
Visuals