Scenario YAML
Review goals, waits, dynamic obstacles, and assertions as code in pull requests.
Write navigation scenarios in YAML, run them from one CLI, then rank planners on a leaderboard, watch quality trend across commits, and replay trajectories over the map.
python3 -m pip install -e .
nav2_scenario_runner init .
nav2_scenario_runner run scenarios/ \
  --report-dir reports/ \
  --html-report index.html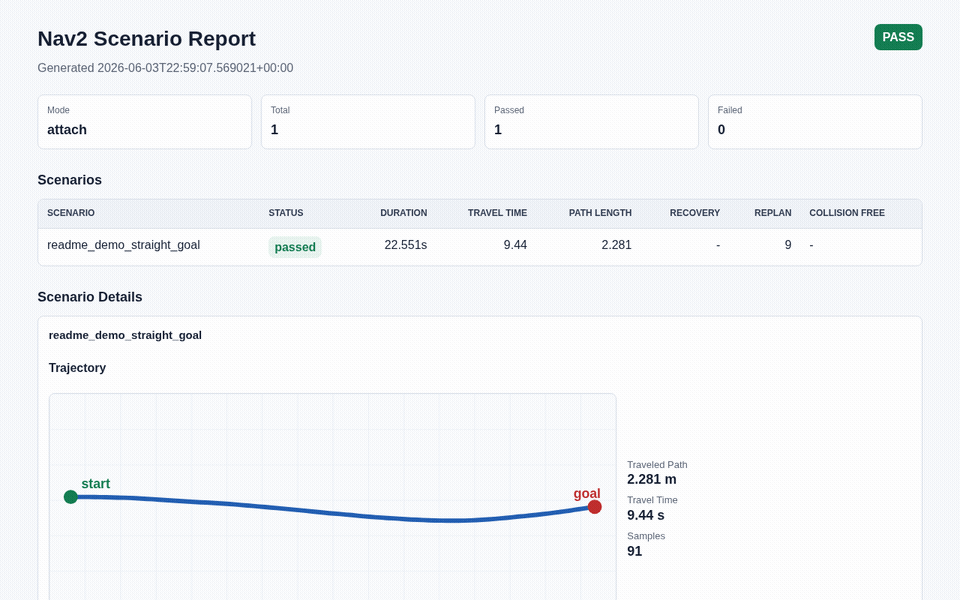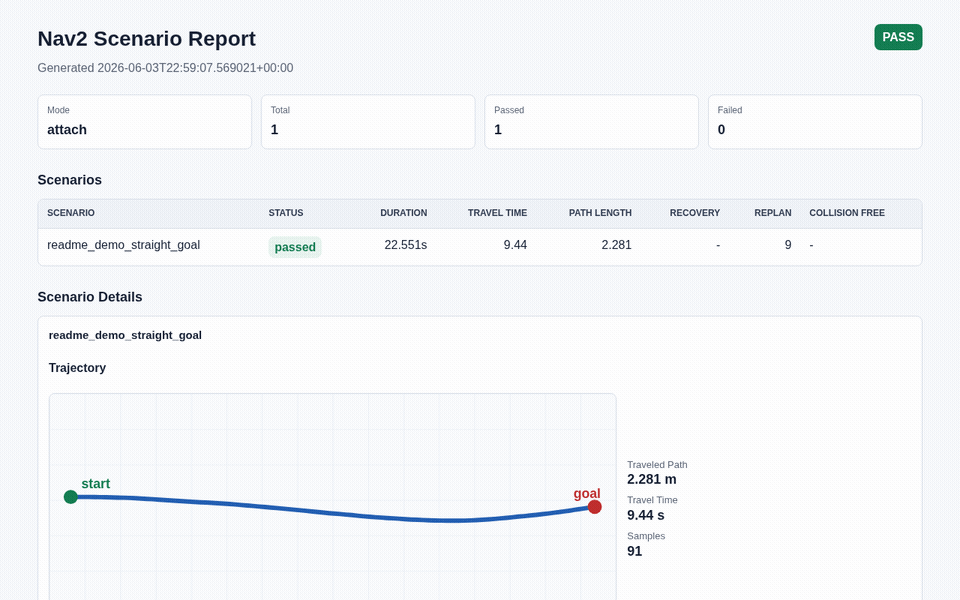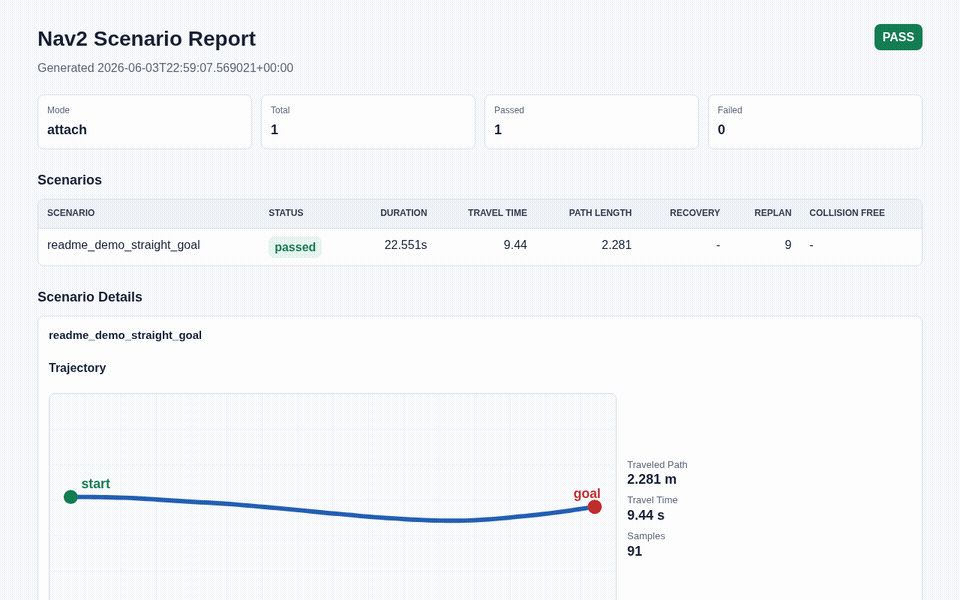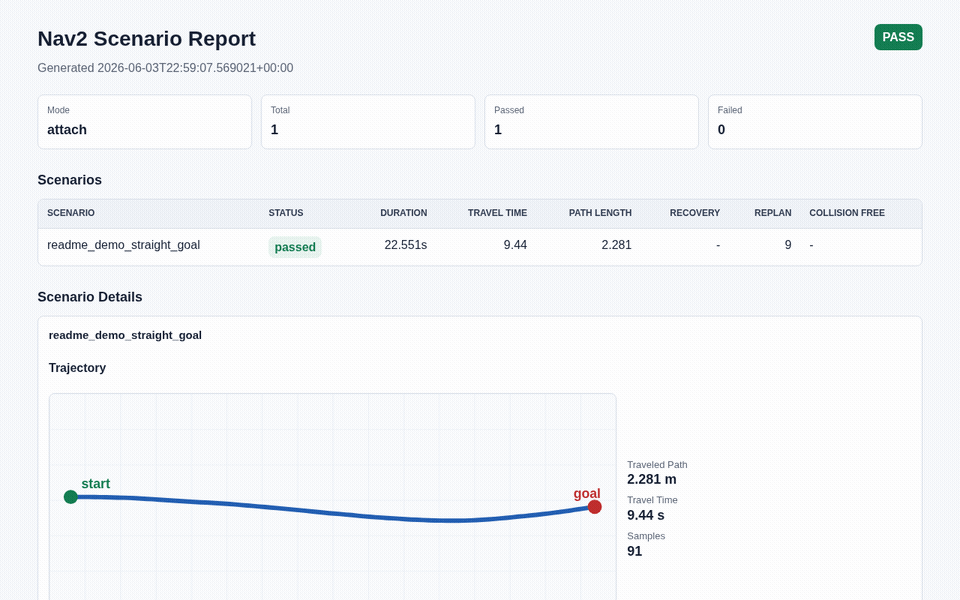
Generated by the runner itself on every deploy — each one a single self-contained HTML file.
Live metrics from the
Nav2 Real Benchmark
workflow — a full ROS 2 Jazzy + Nav2 + Gazebo stack navigating the
tb3_sandbox world on a GPU-less runner. The job
auto-commits each run under
examples/benchmark/real/,
so this updates itself every week.
Scrub the robot along the real /odom trajectories over the tb3_sandbox occupancy map.
Pass rate and real travel_time / path_length across each weekly real-stack run.
Representative fixtures (navfn / smac / teb) from the example benchmark suite so multi-planner comparison renders deterministically without a GPU/sim.
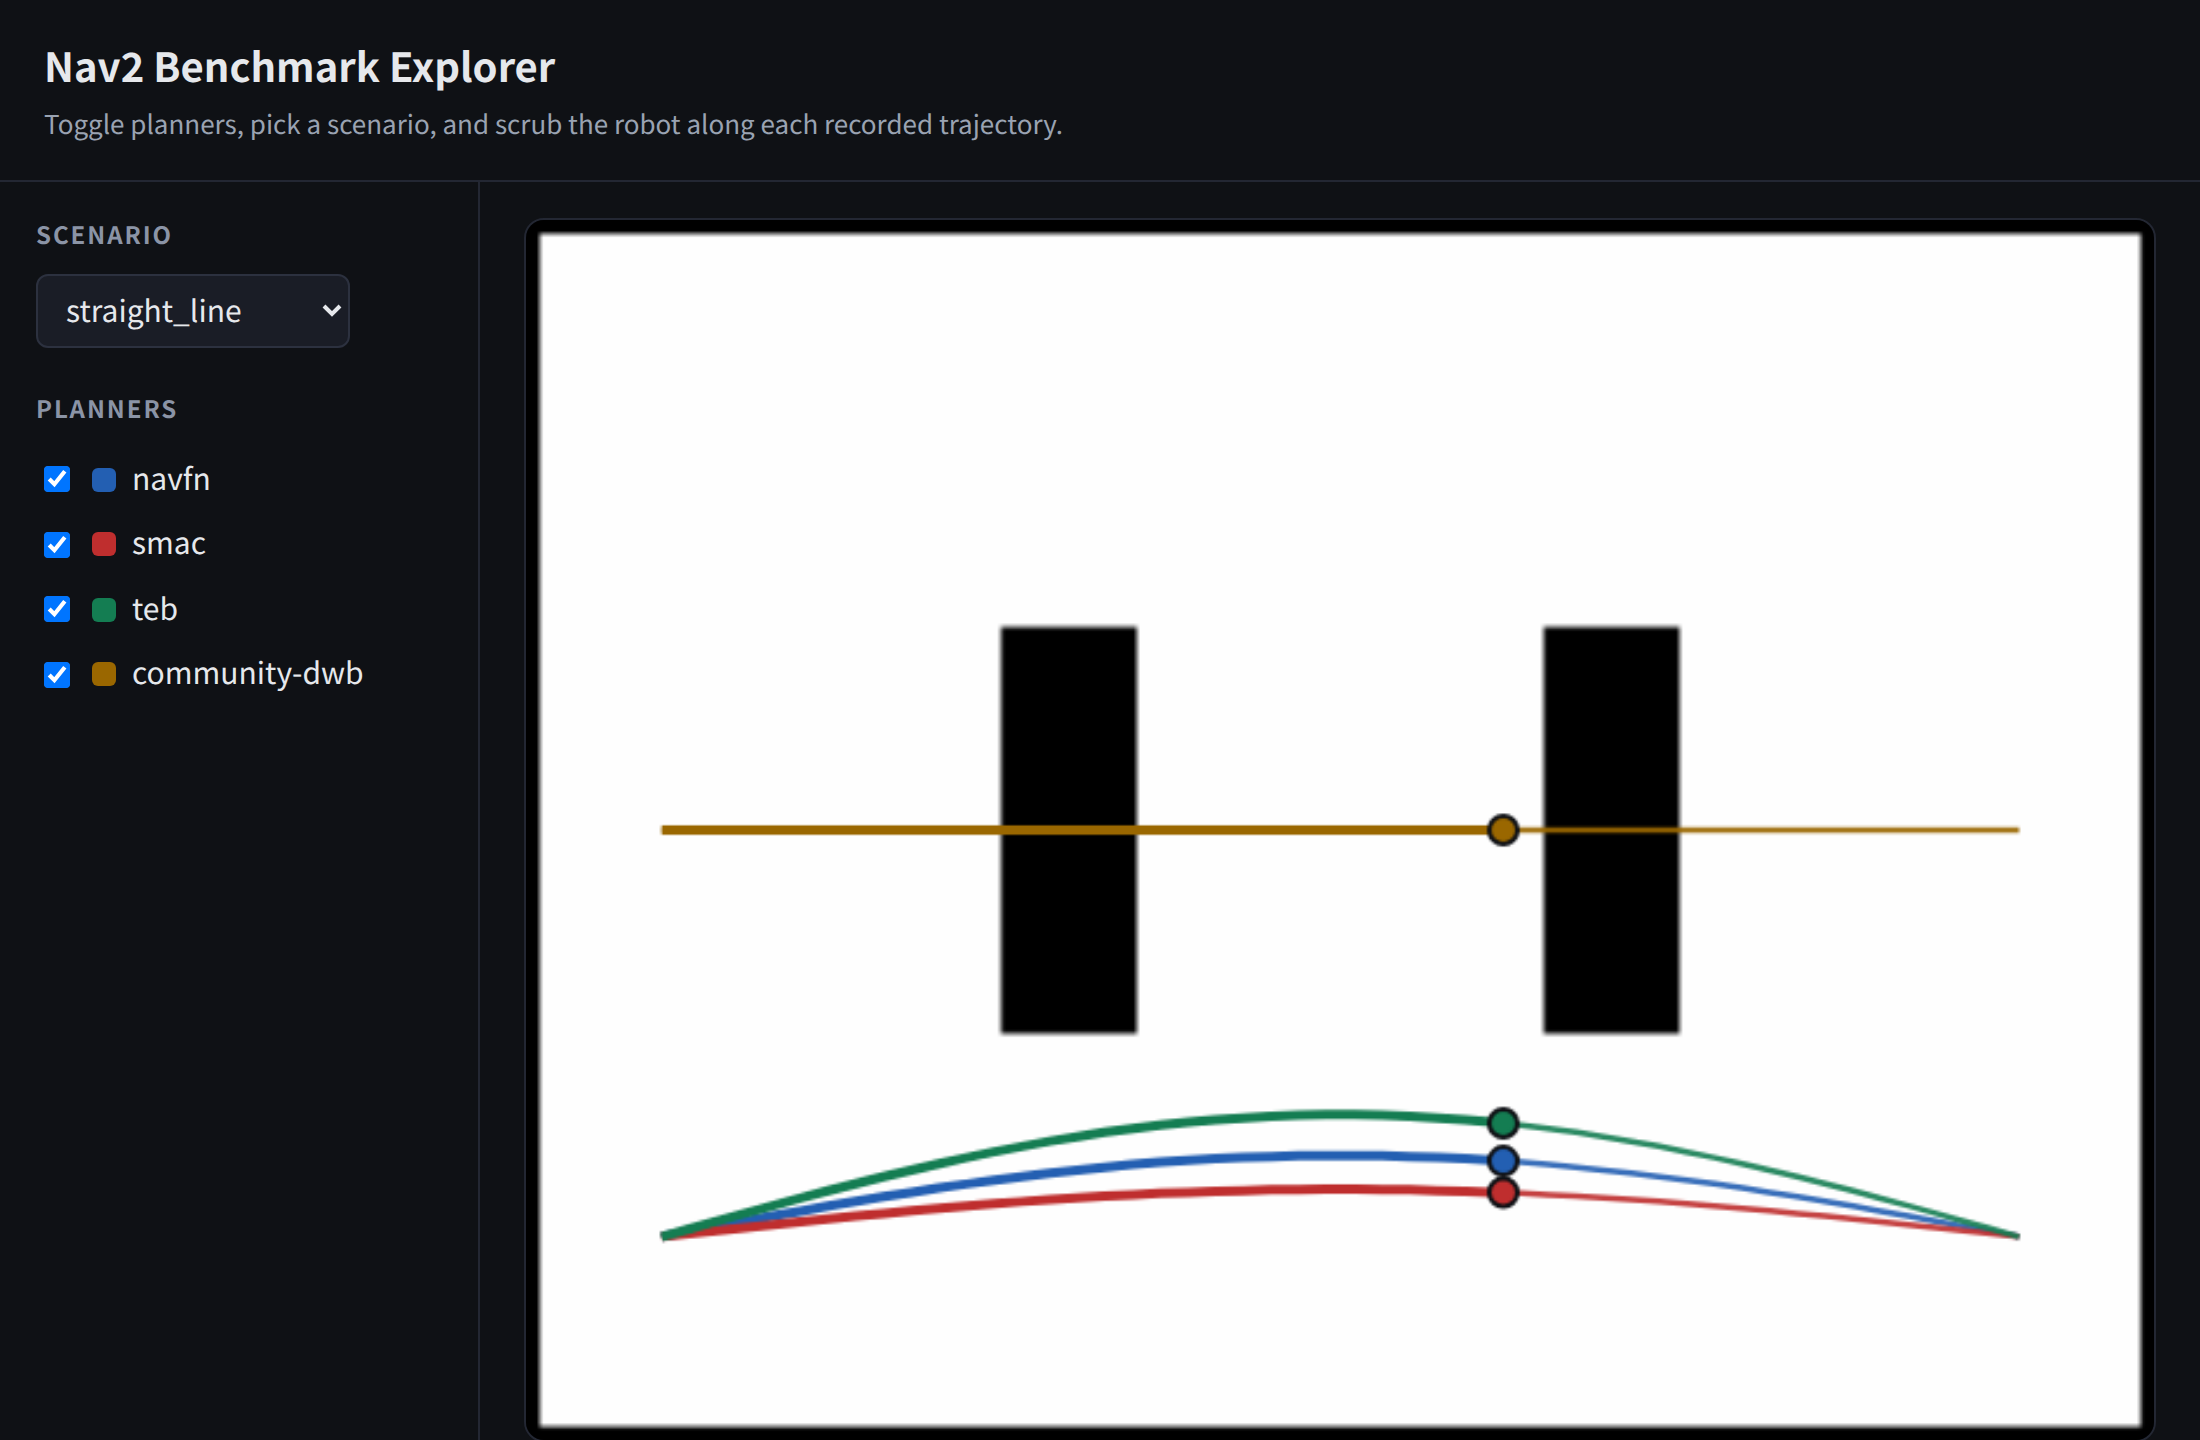
Toggle planners, pick a scenario, and scrub/play the robot along every trajectory over the live map.
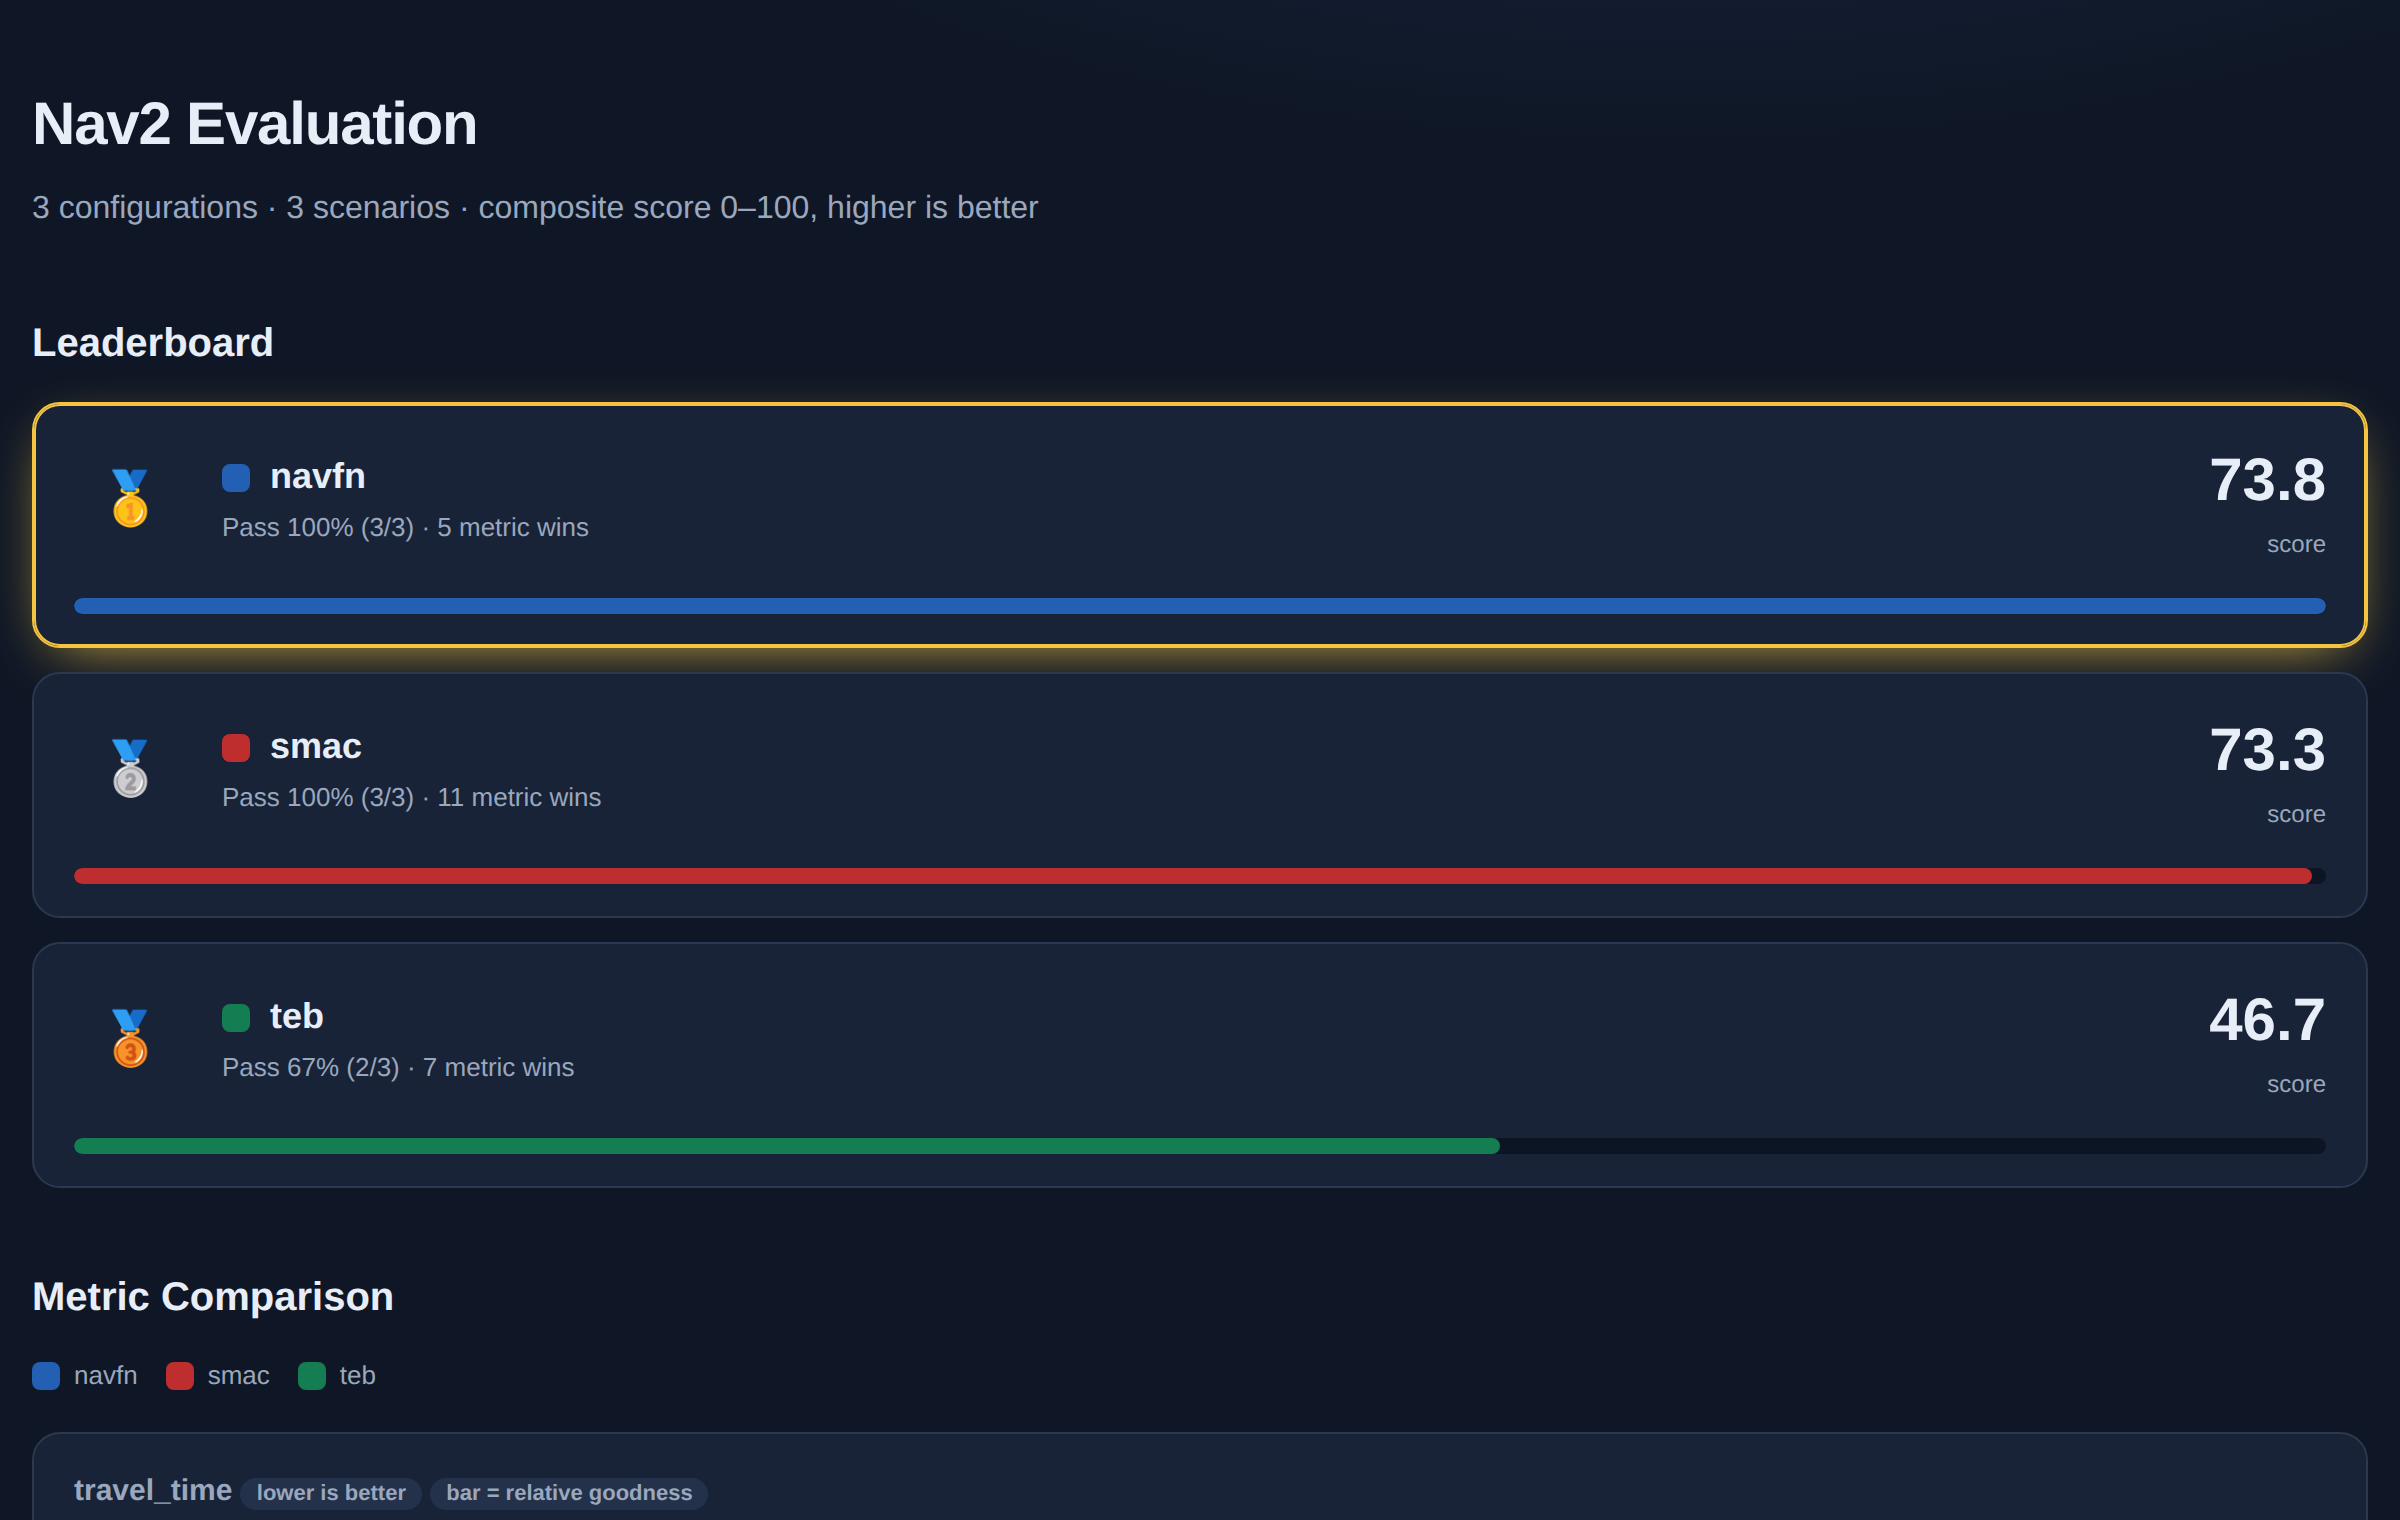
Rank planners 0–100 across a scenario suite with metric-comparison bars.
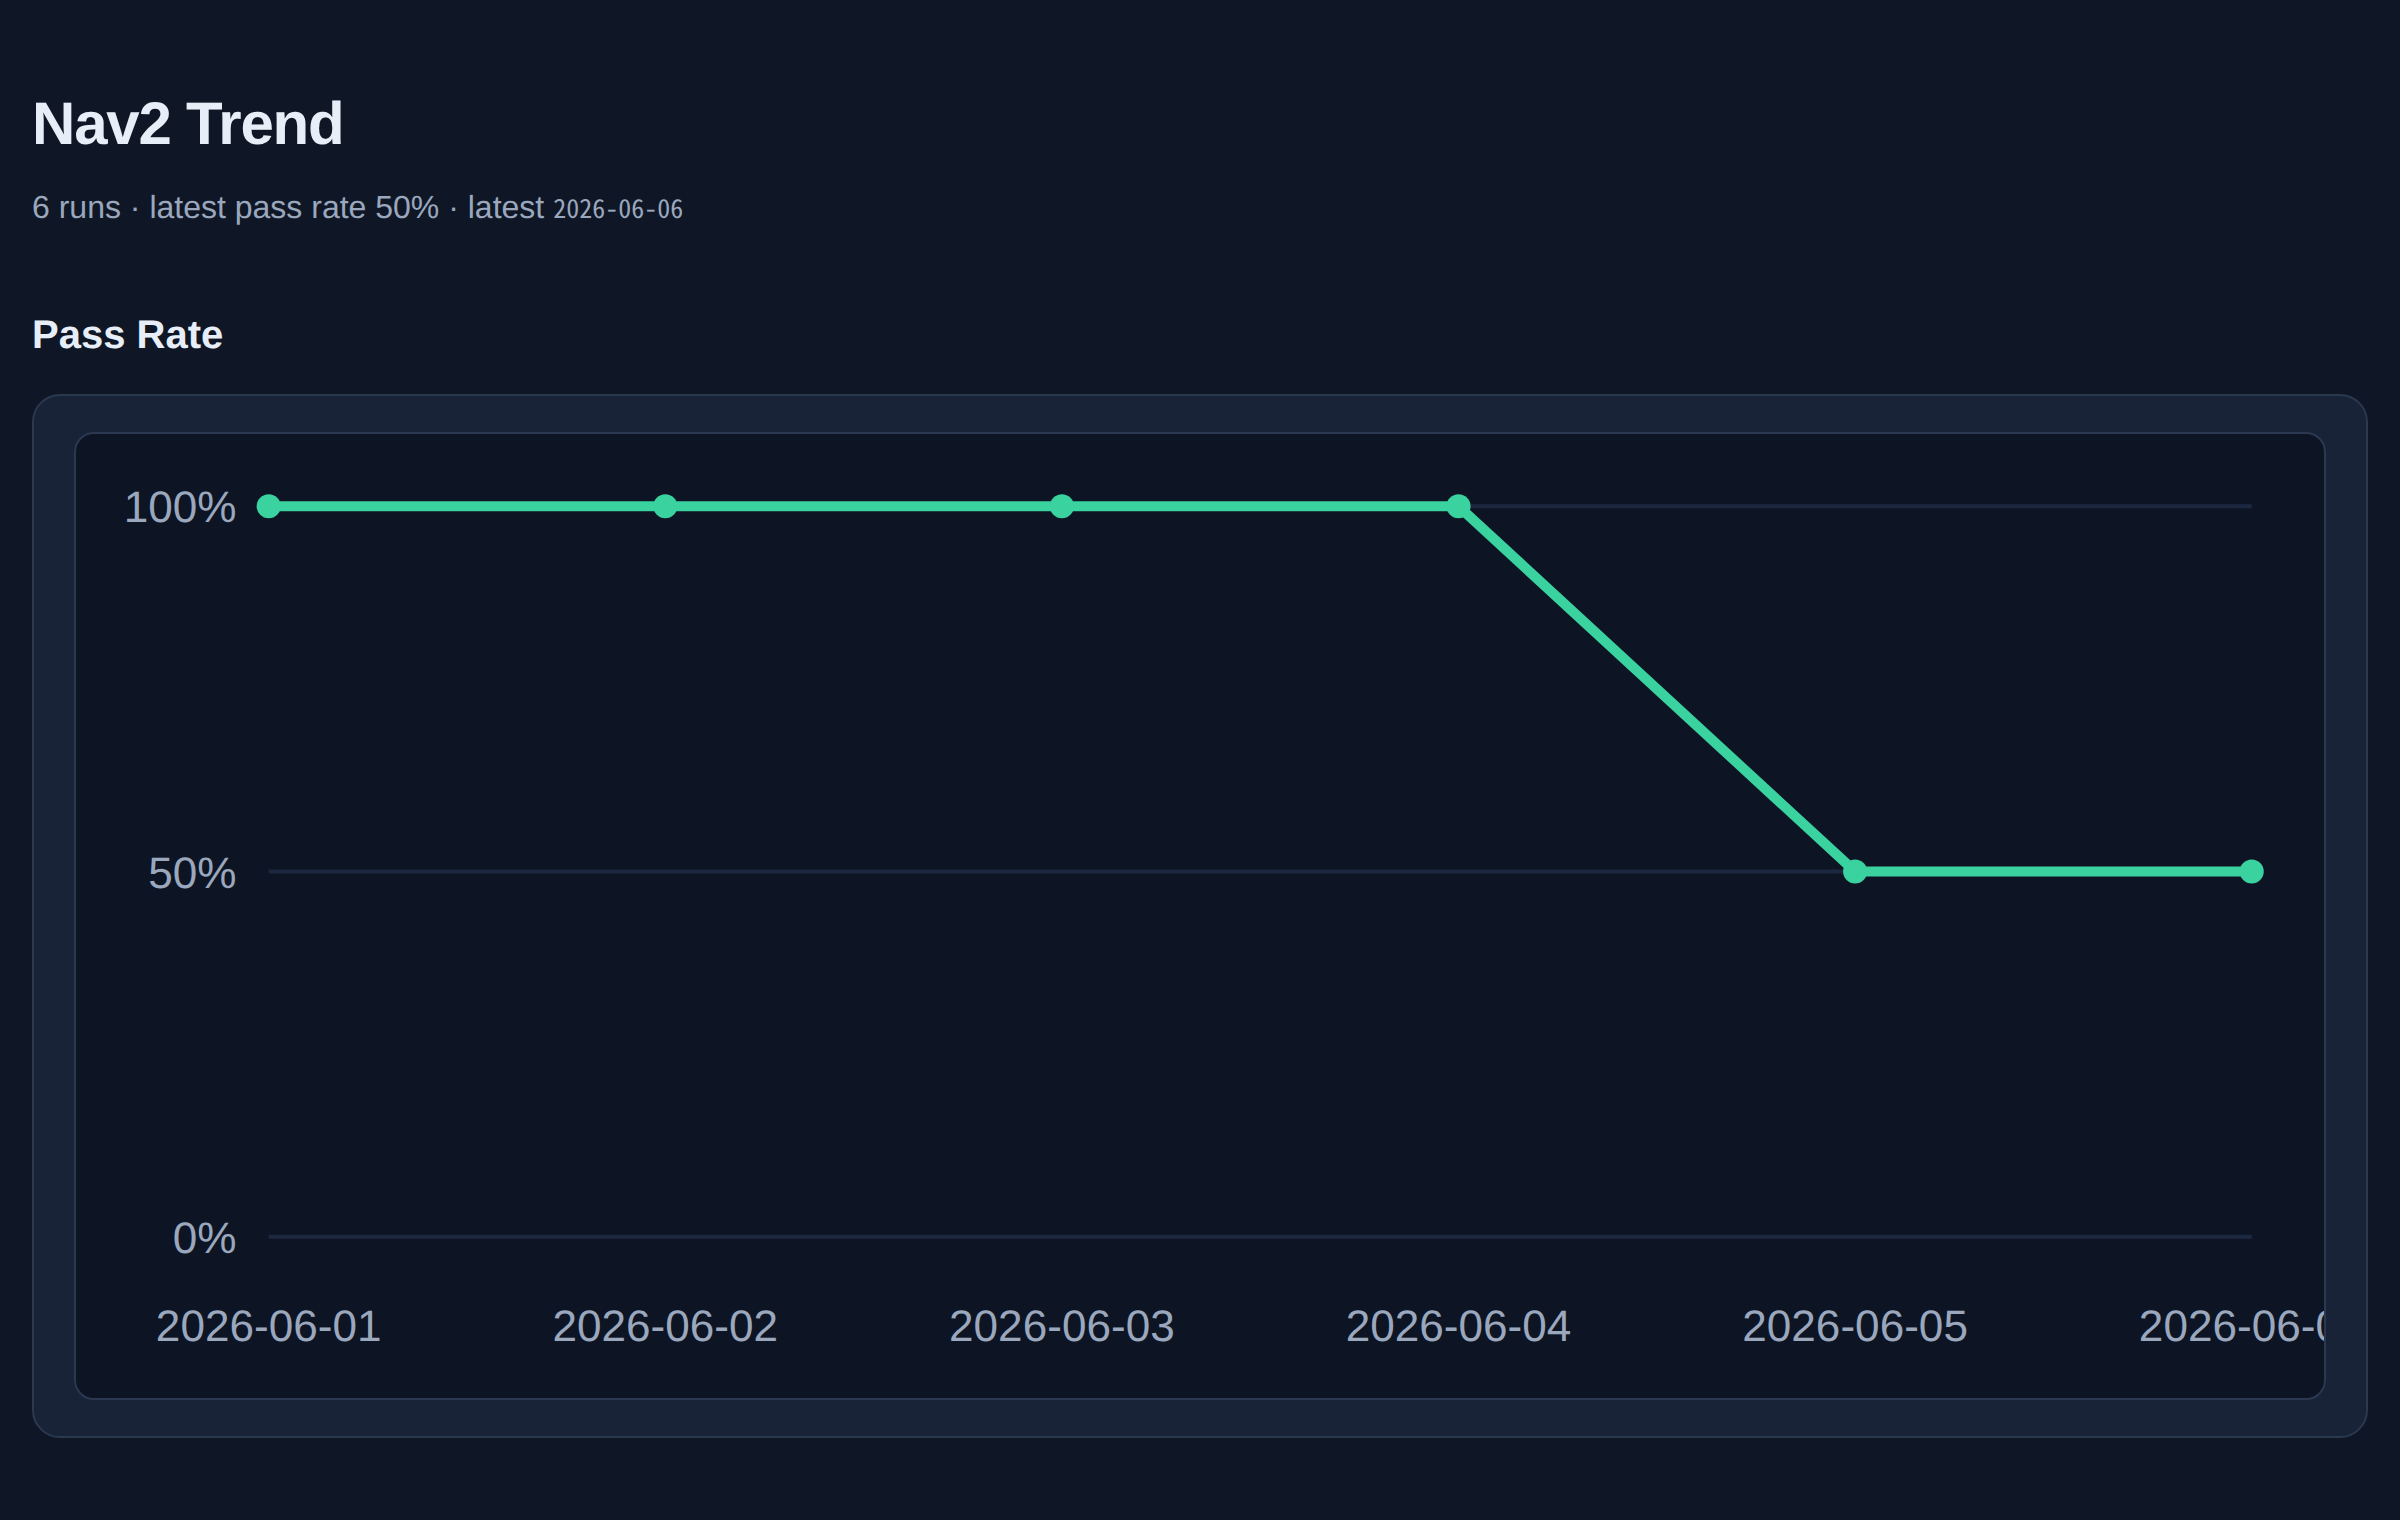
Watch pass rate and per-scenario metrics drift across commits to catch regressions.
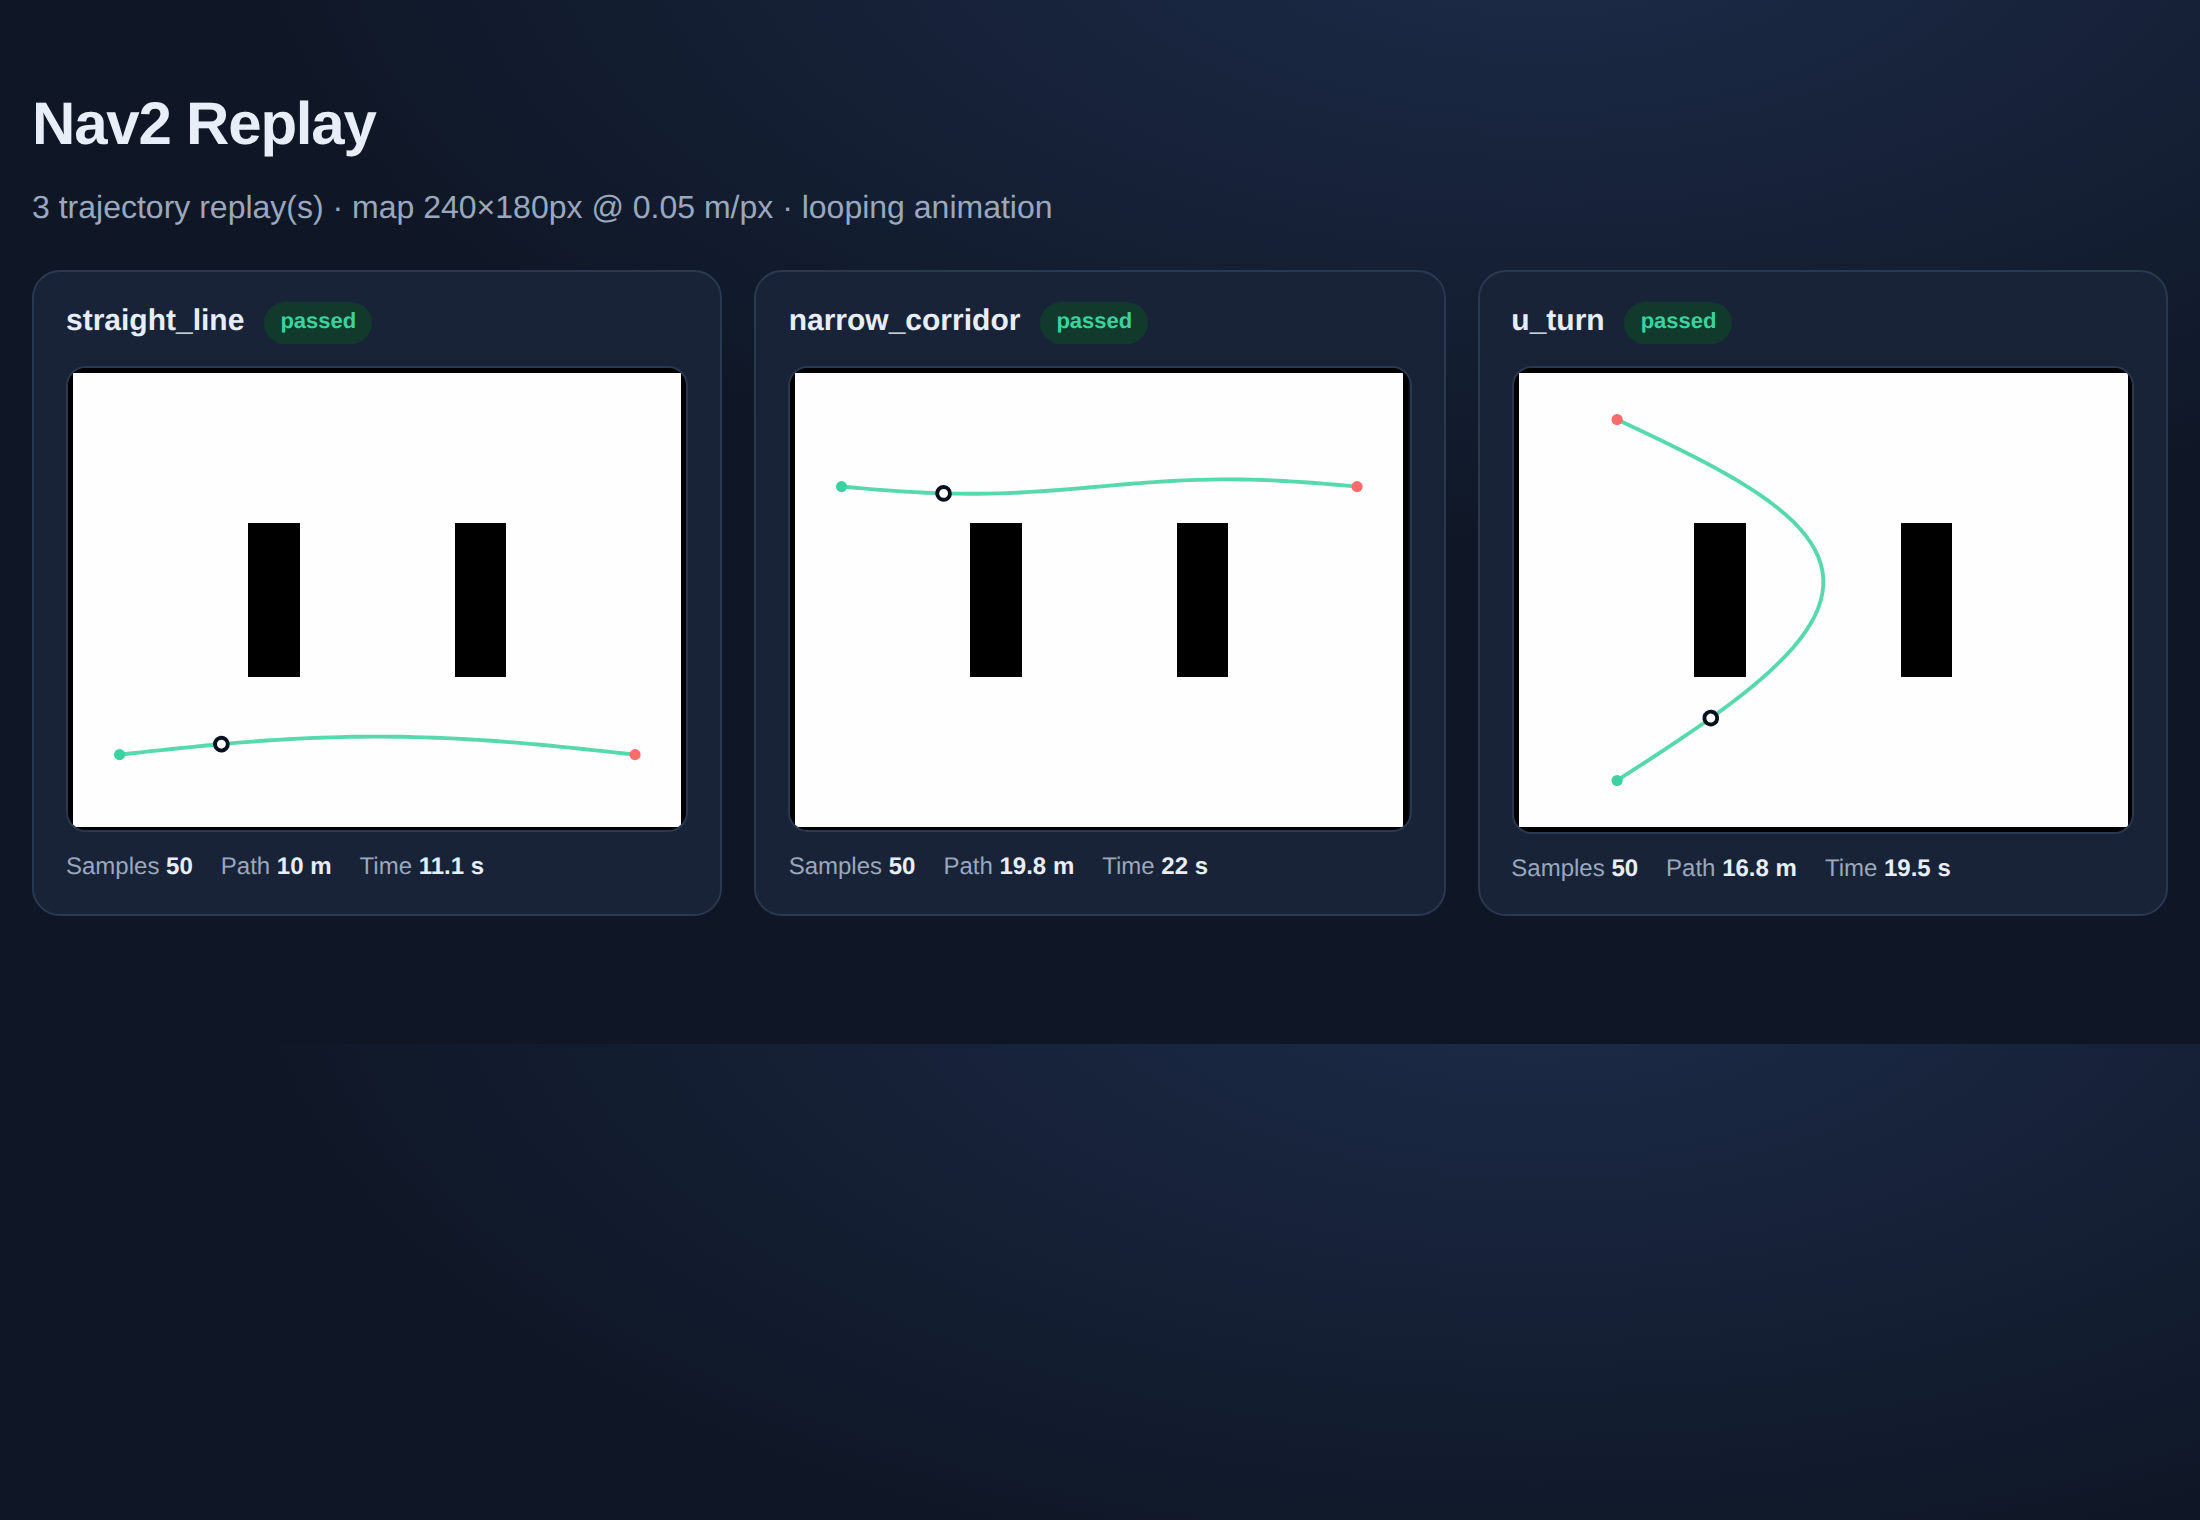
Animate the robot along its /odom path over the real occupancy grid.
Reproduce locally: bash scripts/build_dashboards.sh
Review goals, waits, dynamic obstacles, and assertions as code in pull requests.
Track goal success, travel time, path length, replans, recoveries, and collision signals.
Emit JSON, JUnit XML, Markdown, HTML reports, GitHub summaries, and trace timelines.
apiVersion: nav2.scenario/v1alpha1
kind: Scenario
metadata:
  name: straight_line_goal
  tags: [smoke, navigation]
steps:
  - wait_for_nav2_active: {timeout: 30}
  - set_initial_pose: {x: 0, y: 0, yaw: 0}
  - send_goal:
      name: main_goal
      pose: {x: 10, y: 0, yaw: 0}
  - expect_goal_reached:
      goal: main_goal
      timeout: 60
assertions:
  - goal_reached: {}
  - path_length: {max: 13.0}
- travel_time: {max: 60.0}| Scenario | Status | Time | Path | Replan |
|---|---|---|---|---|
| straight_line_goal | passed | 9.44s | 2.28m | 9 |
| dynamic_obstacle | warning | 31.8s | 11.4m | 6 |