ROS 2 underwater localization
aqua_localization
Real AUV/ROV replays for IMU, pressure, DVL, sonar registration, pose graphs, and underwater 3DGS artifacts.
Public-data replays.
Each visual below is generated from a recorded underwater demo bag and links back to reproducible ROS 2 bring-up notes.
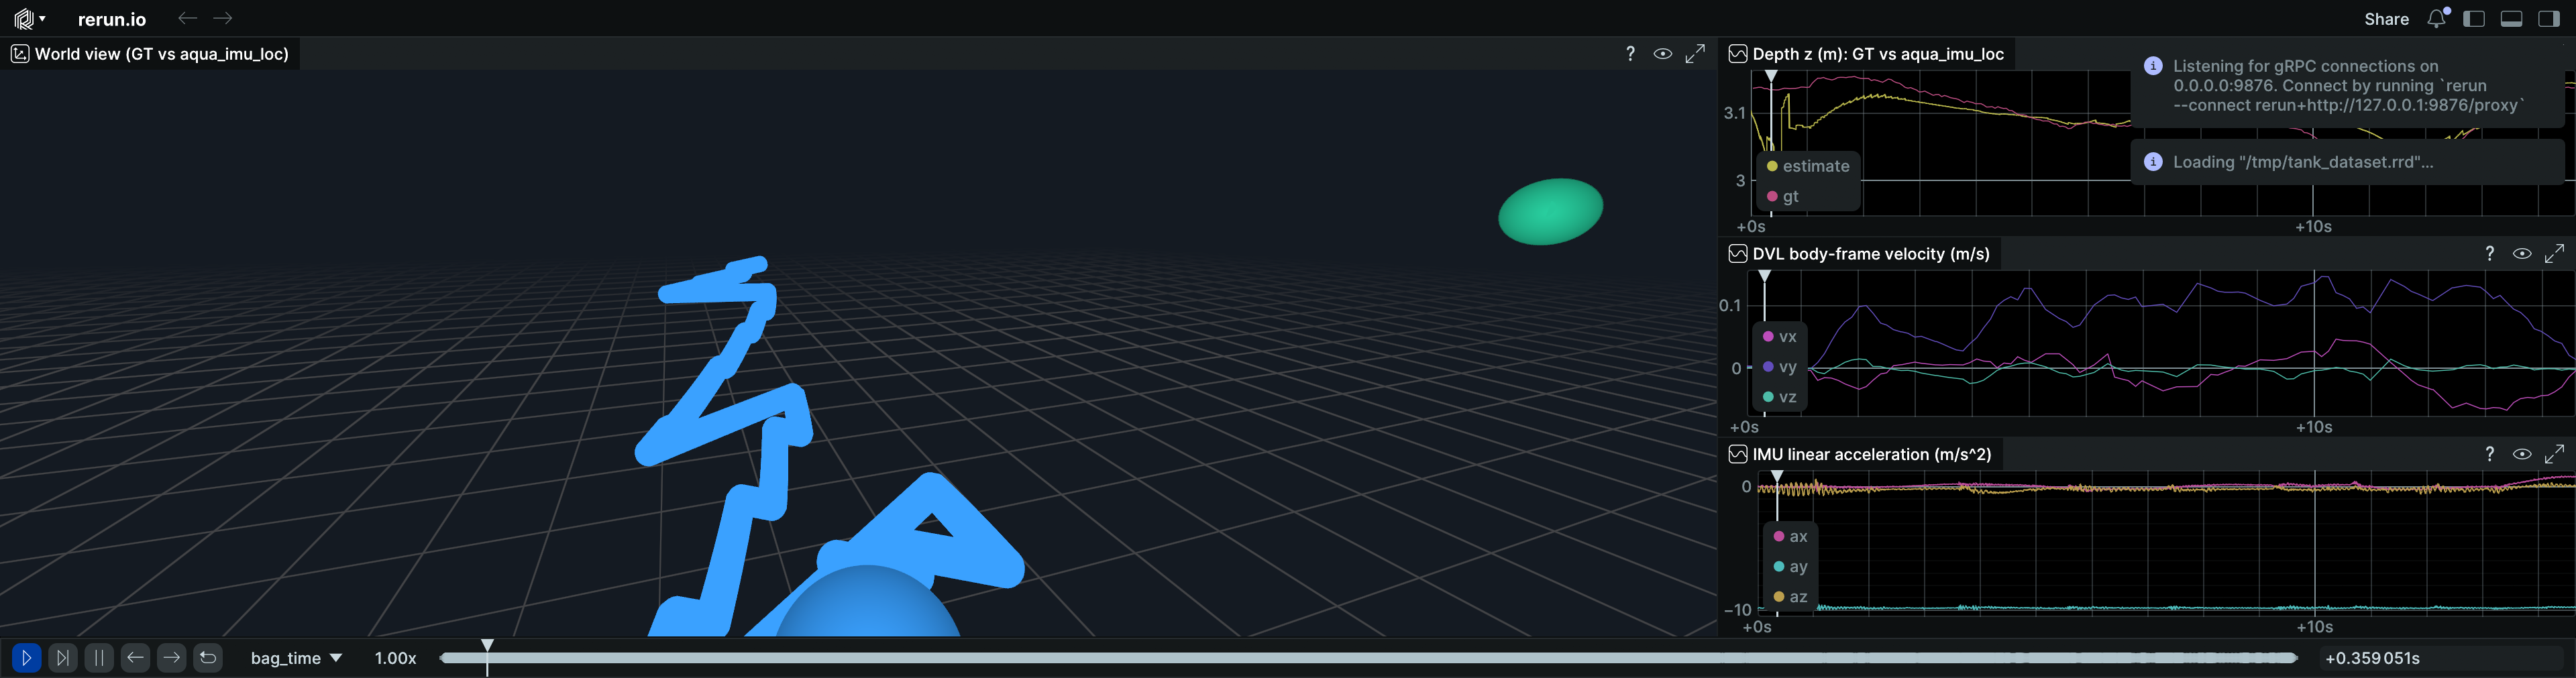
Tank Dataset
DVL + pressure localization with AprilTag ground truth and 0.43 m APE RMSE.
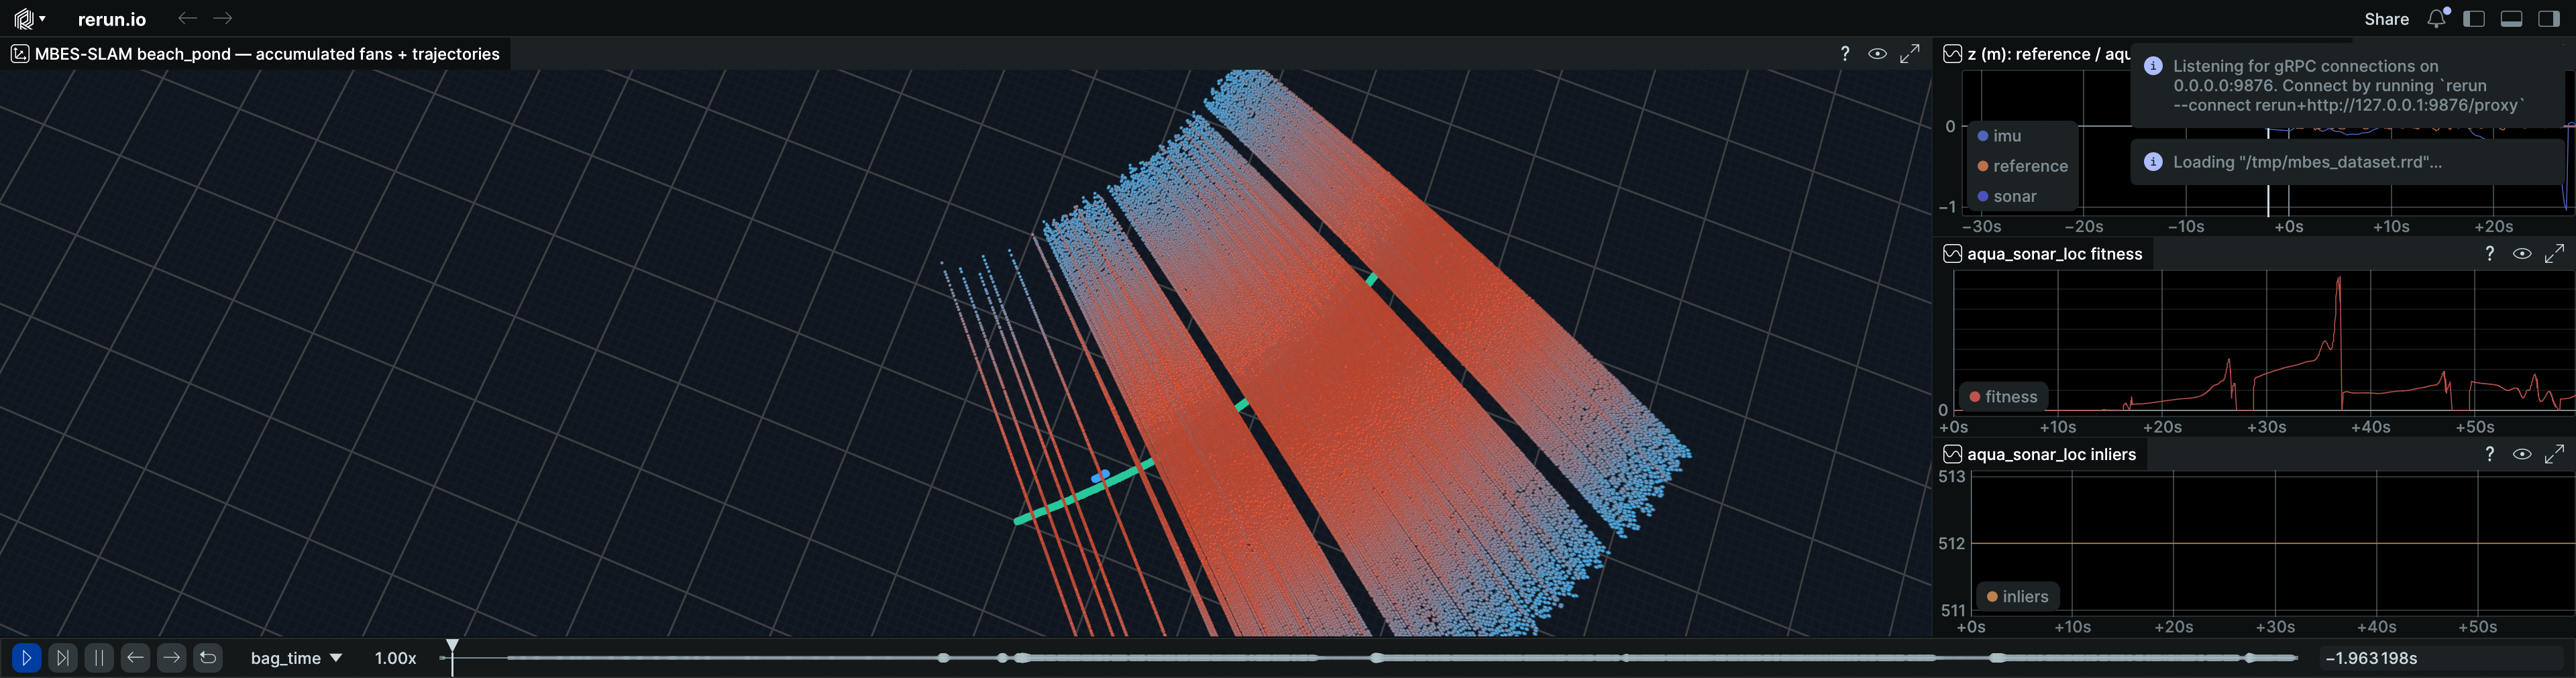
MBES-SLAM
Multibeam fans accumulated into a depth-colored bathymetric scan.
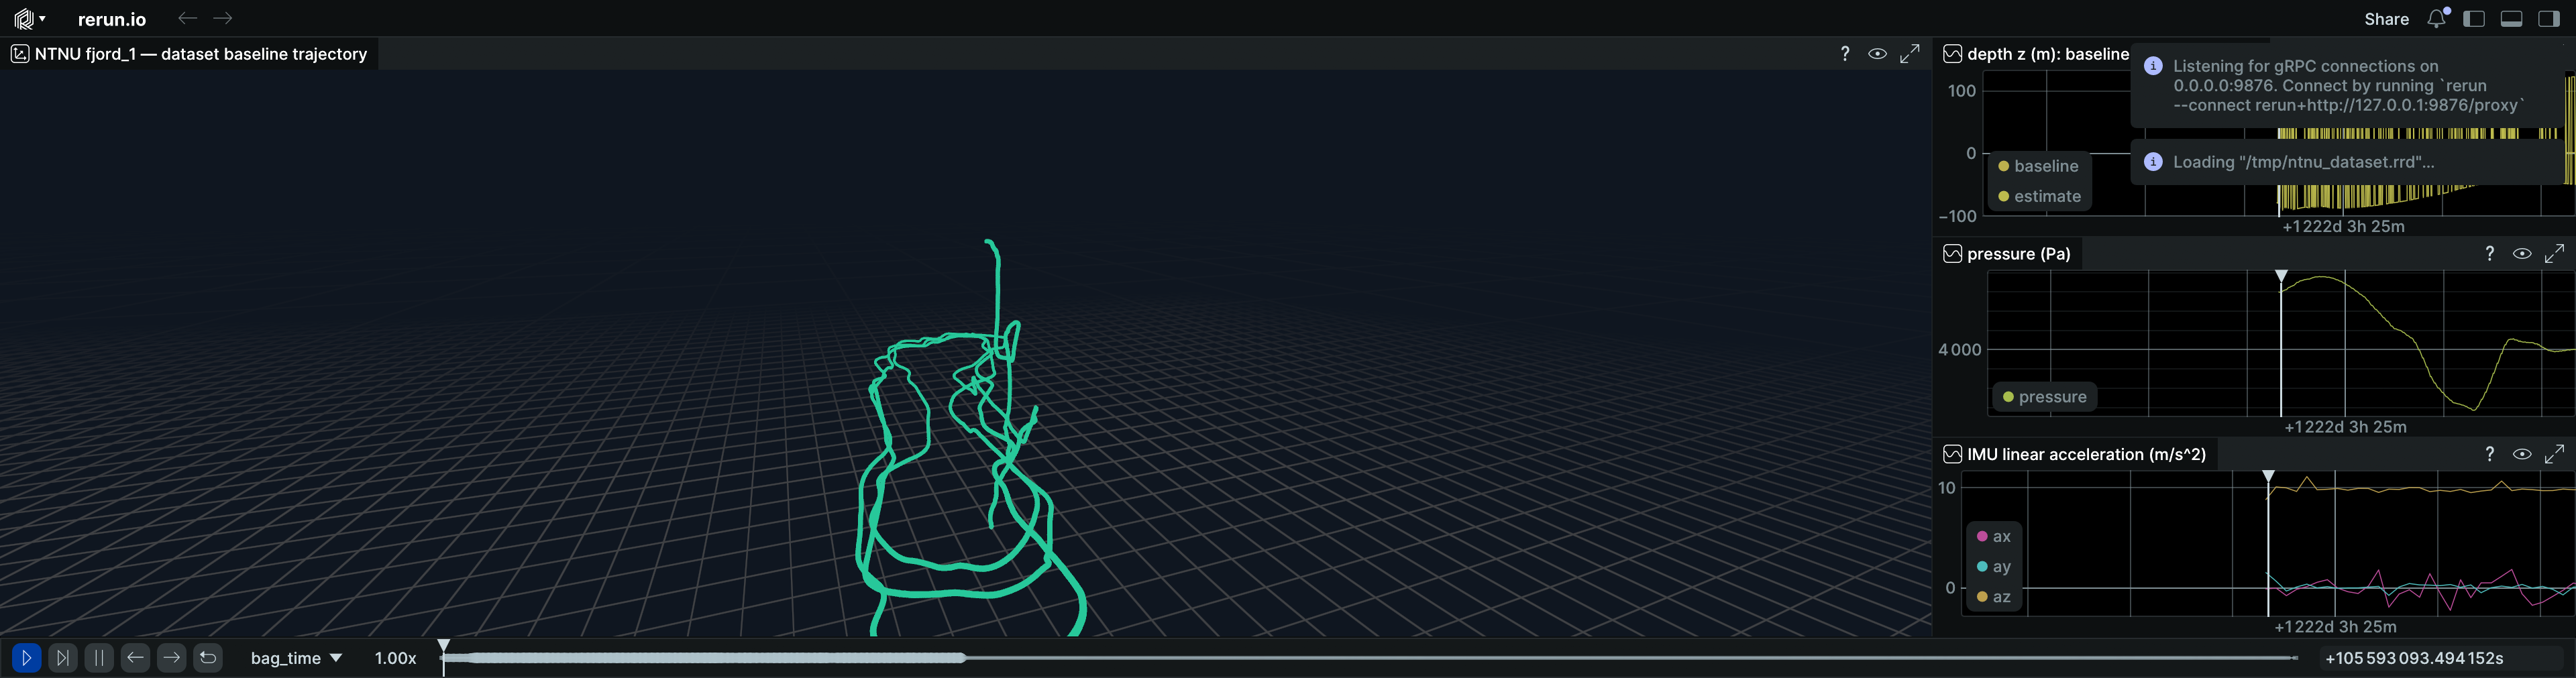
NTNU Fjord
Dataset SLAM baseline through a 7 m fjord dive with depth tracking.
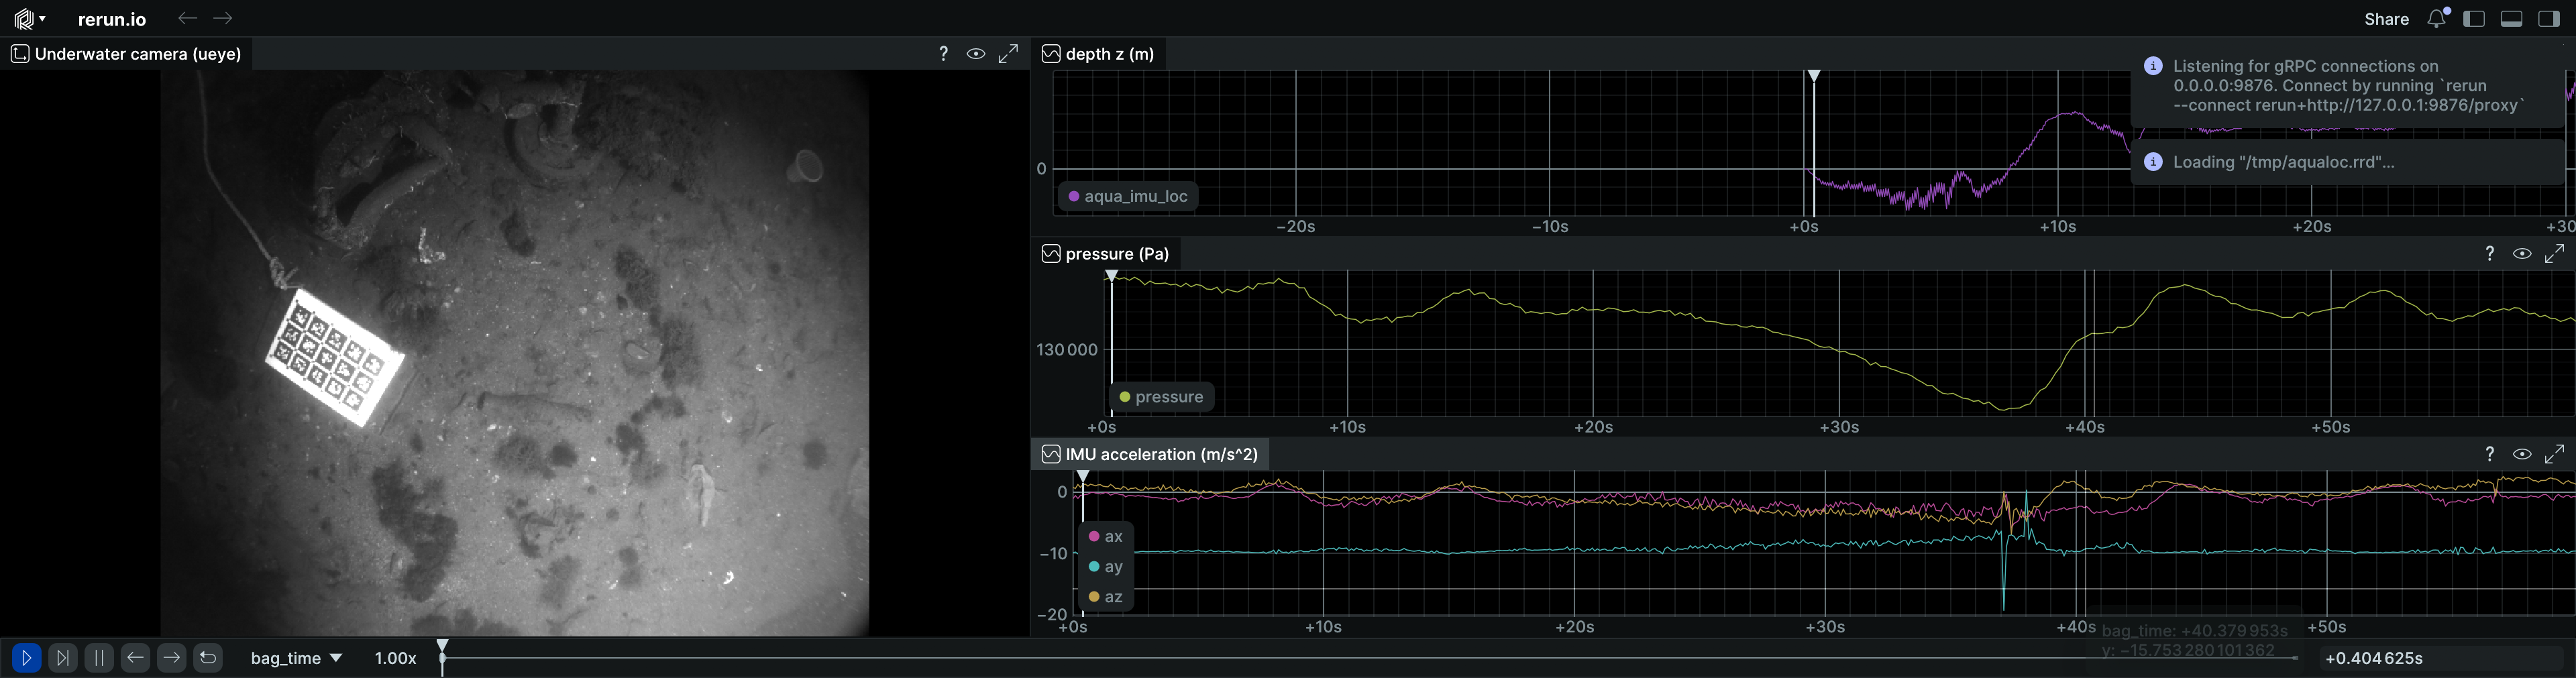
AQUALOC
LIRMM Dumbo ROV camera replay with pressure-derived depth track.

Underwater 3DGS sample
Inspect the Tank sample before downloading it.
The viewer plays 20 real Tank Dataset frames, matched poses, manual stereo intrinsics, and a nerfstudio-style sample pack path.
Built around underwater-specific failure modes.
The stack keeps pressure depth, vehicle-frame DVL, sonar ambiguity, and loop-closure diagnostics explicit instead of hiding them behind generic robot localization plumbing.
Build and launch the ROS 2 stack
Humble and Jazzy commands for the metapackage, launch files, and public bag replay path.
TuneInspect MBES loop-closure candidates
RViz markers and status topics expose accepted, rejected, and gated sonar constraints.
ContributeBring a dataset or benchmark result
Issue templates capture bag source, topics, commands, metrics, and limitations.